 Open Source
SO-ARM102 Open-Source Robotic Manipulator
SO-ARM102 is an open-source robotic manipulator designed for teleoperation and imitation learning.
The device features five degrees of freedom and a parallel gripper, ensuring precise replication of the master manipulator's movements.
The design includes a rigid PET-CF frame and is compatible with the LeRobot platform. This allows the use of existing datasets and control policies.
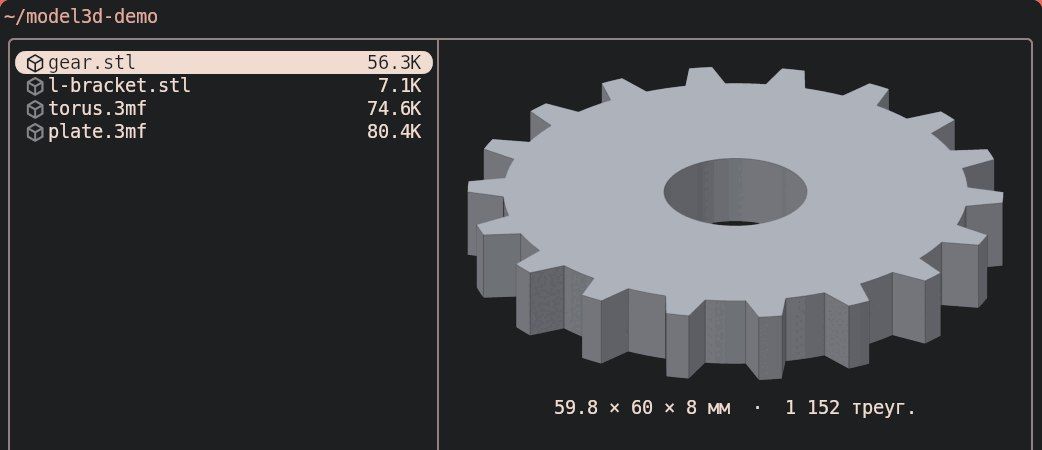
The repository contains files for 3D printing, STEP/STL models, component specifications, and an assembly guide.
- 3D printing files
- STEP/STL models
- Component specifications
- Assembly guide
950 views